Research · robotics
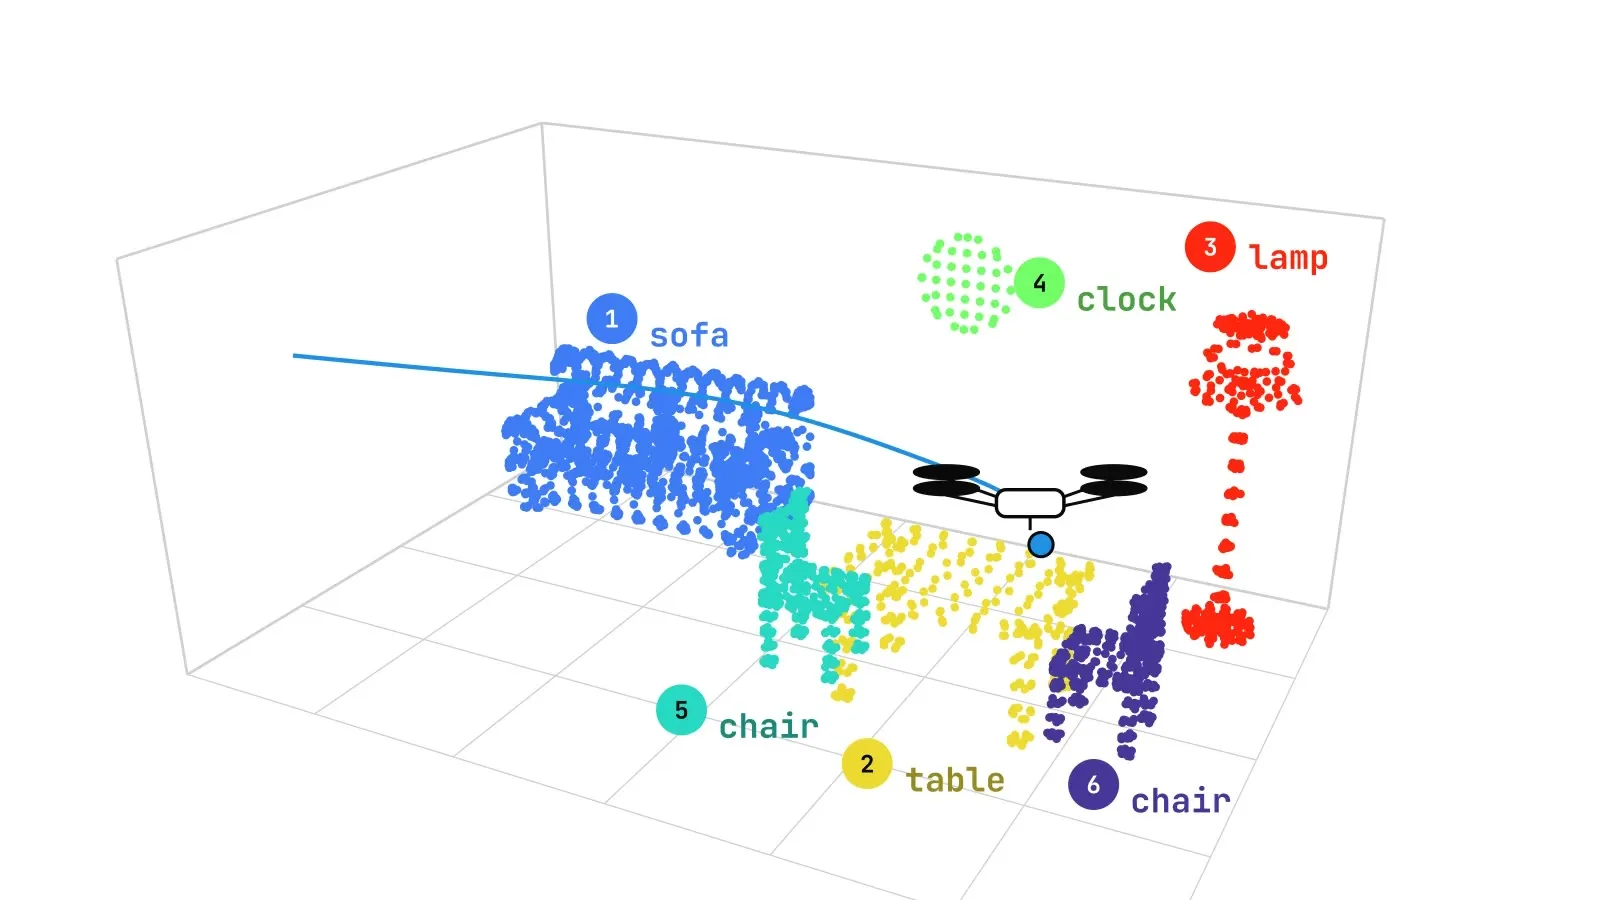
Online Open-Vocabulary 3D Semantic Mapping: Consistent Instances with SLAM
To understand a space, a robot needs to separate every object and know what it is. But those boundaries aren't always clear. Three improvements give more consistent instances and a fusion five times faster.
spatial intelligence · SLAM · Python
Read the case study →